01
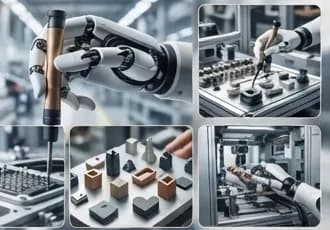
Precision Assembly
Handle small or irregular parts for assembly, tool use, and other human-like process steps.
View candidates50 products →Human-like dexterity expands what robots can do.
A robot hand is the end effector that grasps and manipulates at the tip of an arm or humanoid. Robots working with human tools in human environments need dexterous hands, and the rise of humanoids and embodied AI has made the hand a core component alongside the robot itself. Entry points already span research, education, AI training-data collection, and production and logistics work.
Growing at 68.7% CAGR (interim years interpolated from the growth rate)
Market sizes and growth rates are published forecasts by QYResearch and MarketsandMarkets (checked July 2026).
Find the right robot, faster.
Find your answer in proven use cases.
Deployment is the start. Reliable operation is the goal.
Compare the role of robot hands across industry, healthcare, services, and advanced research.
Handle small or irregular parts for assembly, tool use, and other human-like process steps.
View candidates50 products →
Use EMG, tactile, and force sensing in prosthetics, rehabilitation, and care-support interfaces.
View candidates20 products →
Give service robots the ability to handle human tools and everyday objects.
View candidates38 products →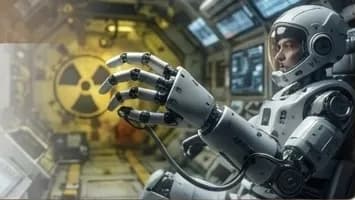
Explore inaccessible environments and new manipulation policies through teleoperation, imitation, and reinforcement learning.
View candidates56 products →Compare each maker's focus, company profile, and representative products.
From six-active-DoF models to higher-dexterity hands, teleoperation, and data collection.
Founded in 2023 in Beijing, Linkerbot combines high-DOF dexterous hands with teleoperation and data systems for embodied AI.
Official website ↗Application-specific multi-finger hands with 11–21 total DoF
Product range spanning linkage and tendon transmissions
Data collection with an exoskeleton glove and teleoperation arm
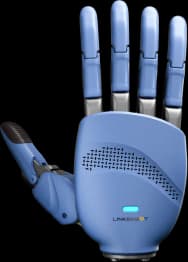
6能動+5受動自由度の軽量・高把持力ロボットハンド。
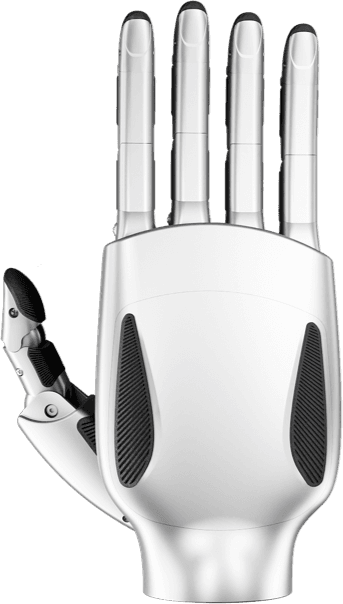
16能動+5受動自由度、触覚・視覚拡張に対応する多指ハンド。
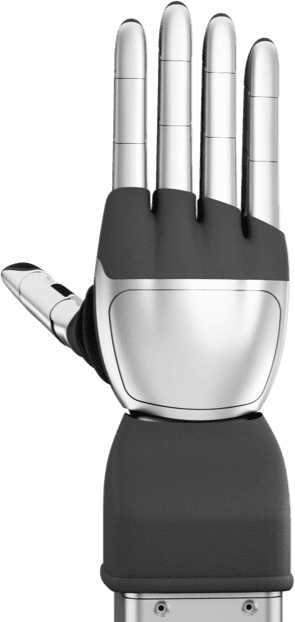
17能動+4受動自由度、腱駆動の高応答ロボットハンド。
Connect dexterous manipulation and learning data through tactile, force, and vision sensing.
Founded in 2024, DexRobot develops dexterous robotic hands, robots, and data-collection platforms, with headquarters and manufacturing in Shaoxing and R&D in Shanghai.
Official website ↗DexHand range from three-finger to integrated wrist-hand designs
Multimodal position, tactile, force, and proximity sensing
Development platform with SDKs, simulation, and teleoperation
Published track record Its official company introduction lists China Post, Xiaomi, NVIDIA, and others as partners.
Industrial two-finger grippers with practical payload, stroke, and speed choices.
Founded in 2018 in Taicang, Jiangsu, ChangingTech develops and manufactures collaborative, parallel, dexterous, and heavy-duty robot grippers and embodied-intelligence robots.
Official website ↗Practical industrial lineup centered on parallel gripping
Multiple sizes by stroke and payload
Straightforward integration for assembly and machine tending
Apply EMG sensing and bionic technology to multi-finger robot hands.
Founded in 2015 in Shanghai Zhangjiang, OYMotion develops brain-computer interfaces, EMG/EEG sensing, rehabilitation robots, bionic hands, and dexterous robotic hands.
Official website ↗Control technology grounded in EMG and EEG analysis
Experience spanning prosthetics, rehabilitation, and robotics
ROH models with varied DoF and sensing configurations
A long-established research hand specialist focused on dexterity, touch, and teleoperation.
Headquartered in London, Shadow Robot has developed high-dexterity robot hands, tactile sensing, and teleoperation systems for research and industry for over two decades.
Official website ↗High-DoF multi-finger manipulation modeled on the human hand
Research platform with tactile sensing and ROS
Systems designed for reinforcement learning and teleoperation
Published track record Shadow Robot co-developed DEX-EE with Google DeepMind for demanding, long-running machine-learning experiments.
Review every matching model currently listed in the catalog.
Multi-finger hands target complex human-work substitution, research, and embodied AI; compare 12 models by DoF, touch, teleoperation, and learning support. Two-finger grippers instead prioritize payload, speed, and cost on industrial lines.
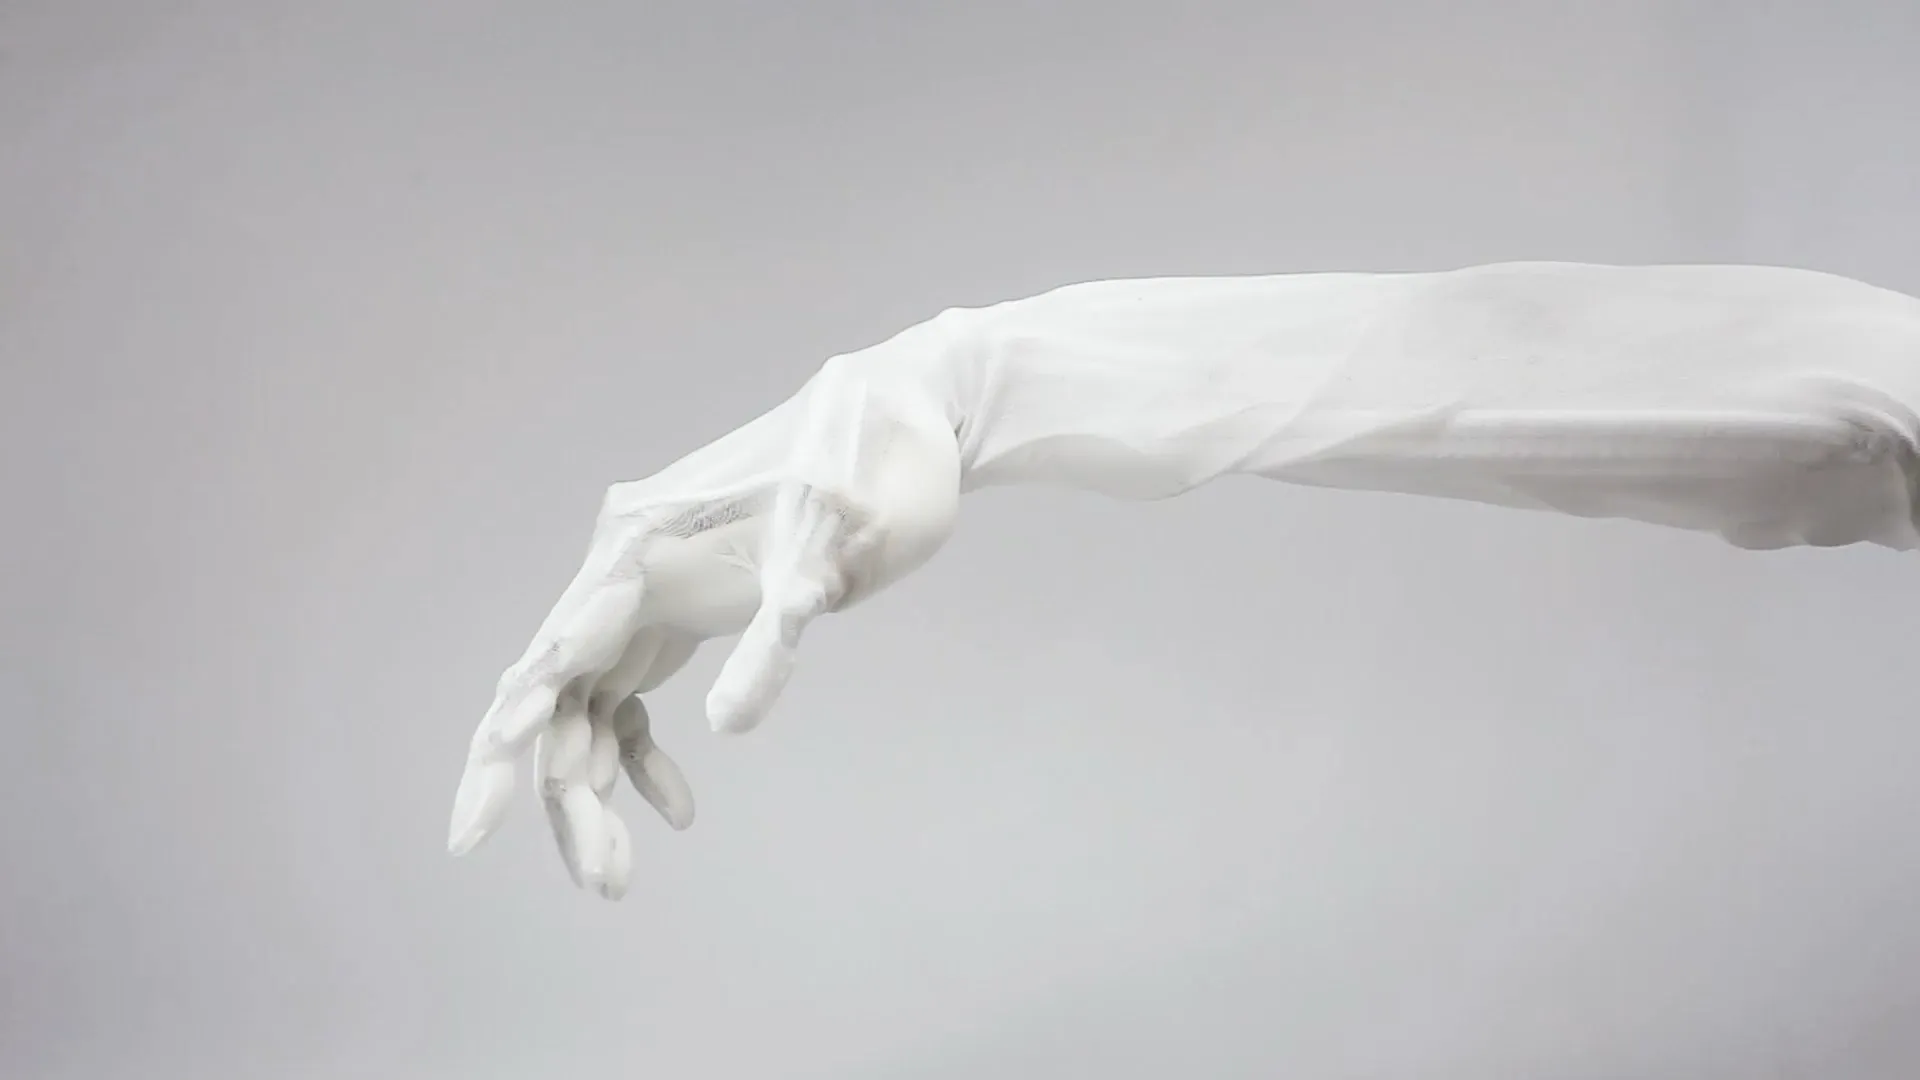
人間の手を模倣したバイオミメティック多指ロボットハンド(Myofiber人工筋肉駆動)

業内初の多次元触覚+AIビジョンデュアルモーダル多指ロボットハンド
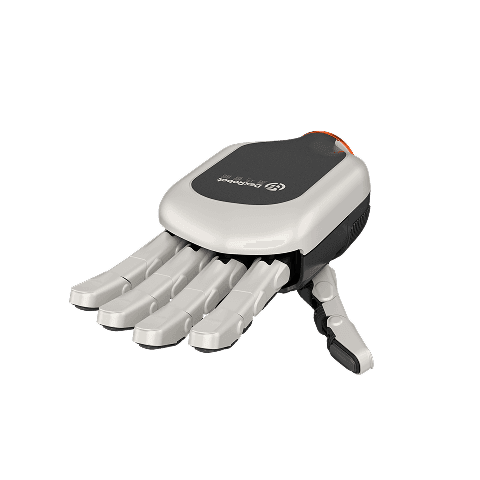
19自由度と位置・力・滑り・近接の多モーダル知覚を備えた量産型ロボットハンド。
手首一体構造と全域マルチモーダル知覚を備えた22自由度ロボットハンド。
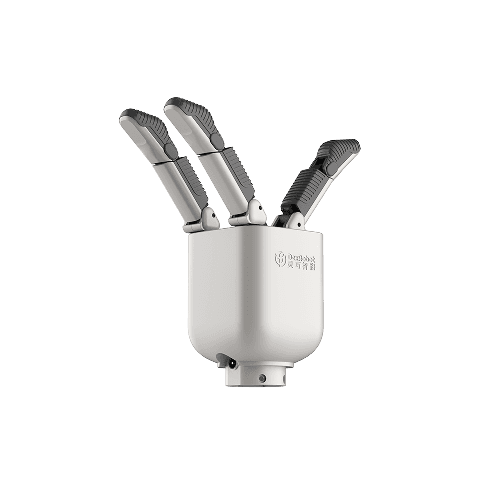
0.6kgの軽量ボディで最大5kg把持に対応する8自由度ロボットハンド。
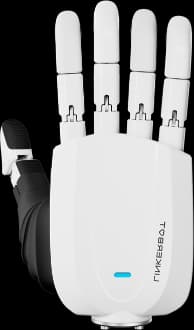
607gのコンパクトな6能動+5受動自由度ロボットハンド。
16能動+5受動自由度、触覚・視覚拡張に対応する多指ハンド。
17能動+4受動自由度、腱駆動の高応答ロボットハンド。
6能動+5受動自由度の軽量・高把持力ロボットハンド。

全25自由度を力制御し、指先から手首まで触覚と力を読み取るNEO搭載用の腱駆動ハンド
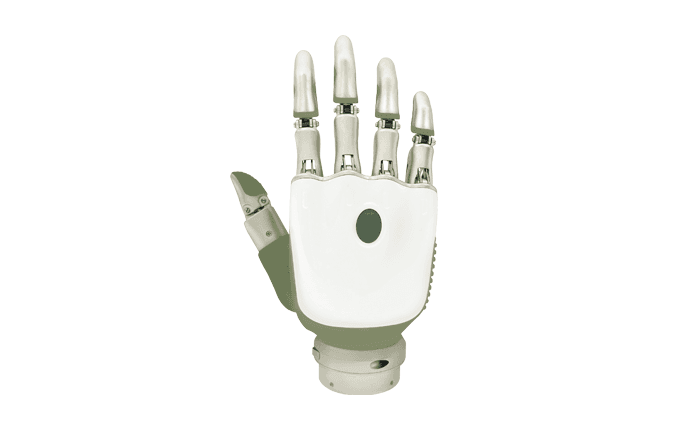
27種類のプリセット動作とアプリ設定に対応する、義手・支援用途向けの5指バイオニックハンド。

10アクティブ+6パッシブの16自由度と300以上の触覚センサーを備えた、汎用性とスケーラビリティを両立した標準型ロボットハンド

350gの小型・高剛性デクスタラスハンド。半身ヒューマノイドやモバイルマニピュレータ向け。

Flagship direct-driven dexterous hand

Flagship tendon-driven dexterous hand

Industrial-grade adaptive gripper engineered for embodied AI manipulation and data collection
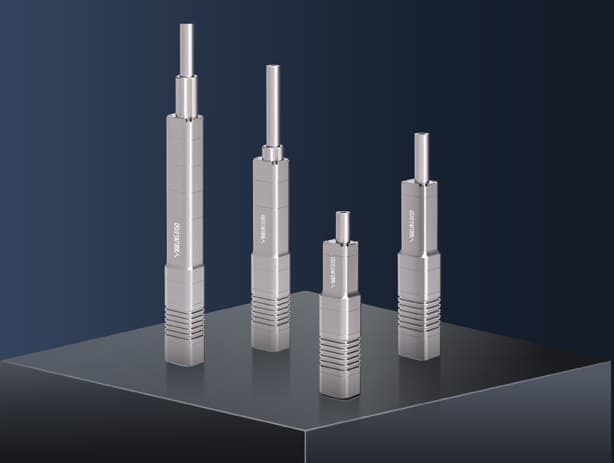
人の手サイズ・軽量540gで大きな握力と高精度を両立した仿人五指ロボットハンド
精準觸覚・実時感知、強靭な把持力を備えた仿人五指灵巧手(デクスタラスハンド)
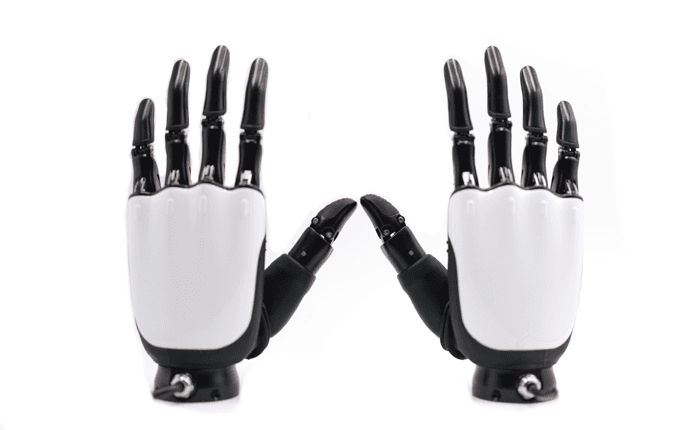
545gの軽量設計で30kgのフック把持荷重に対応する11関節ロボットハンド。
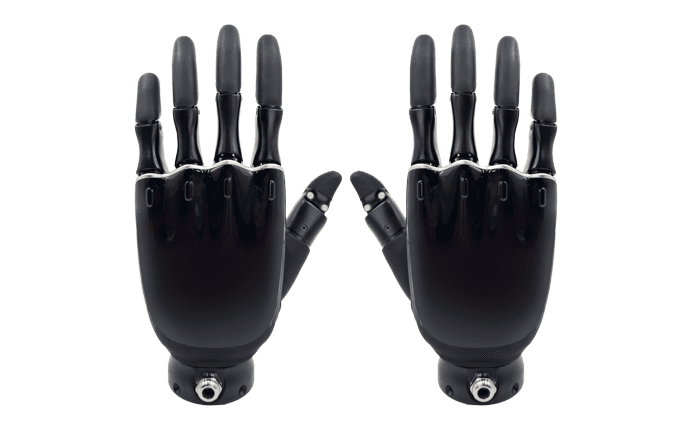
触覚・力覚・位置フィードバックを統合した11関節・6能動自由度の多指ハンド。
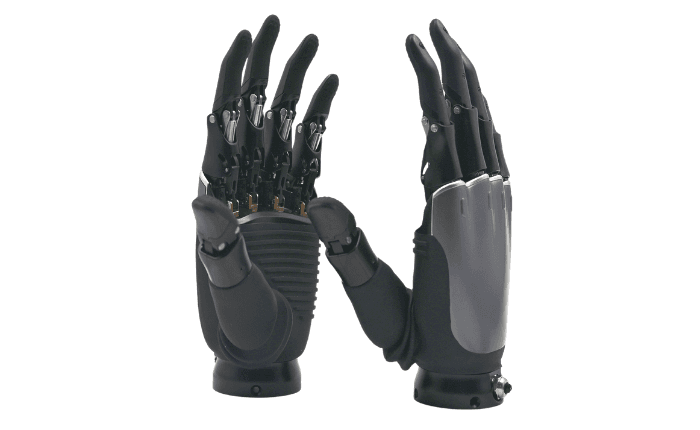
指・掌の3次元力覚と150Hz触覚更新に対応する11関節ロボットハンド。
分布型触覚と全方向3次元力覚を備え、30kgの吊り上げ荷重に対応する多指ハンド。
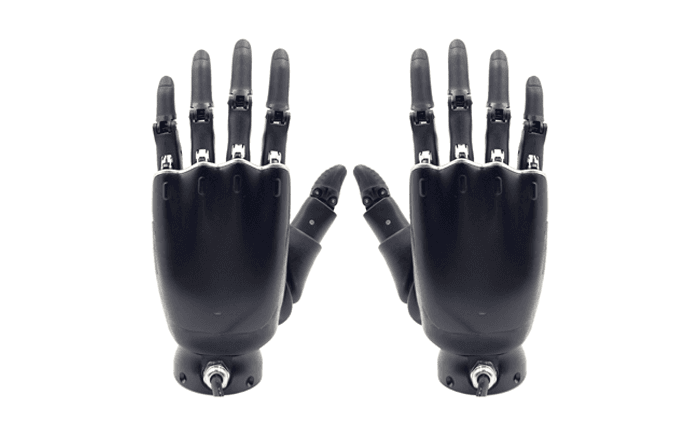
457gの軽量ボディに11関節・6能動自由度と25kg吊り上げ荷重を備えた軽量ロボットハンド。
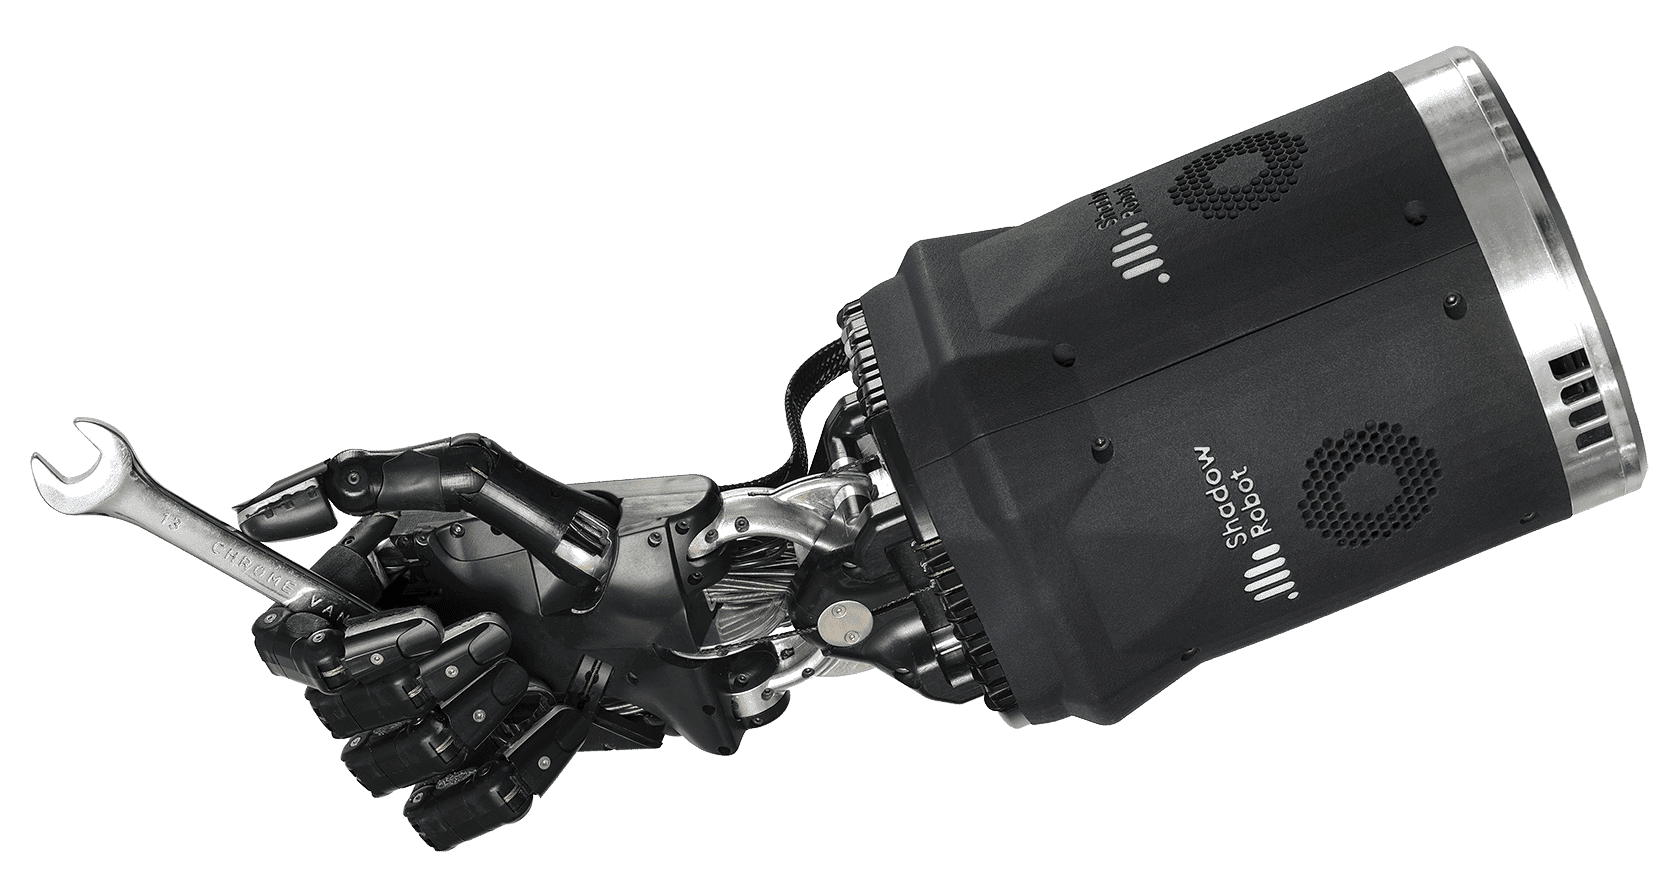
20モーター・24関節と100超のセンサーを備え、1kHz制御に対応する5指ロボットハンド。
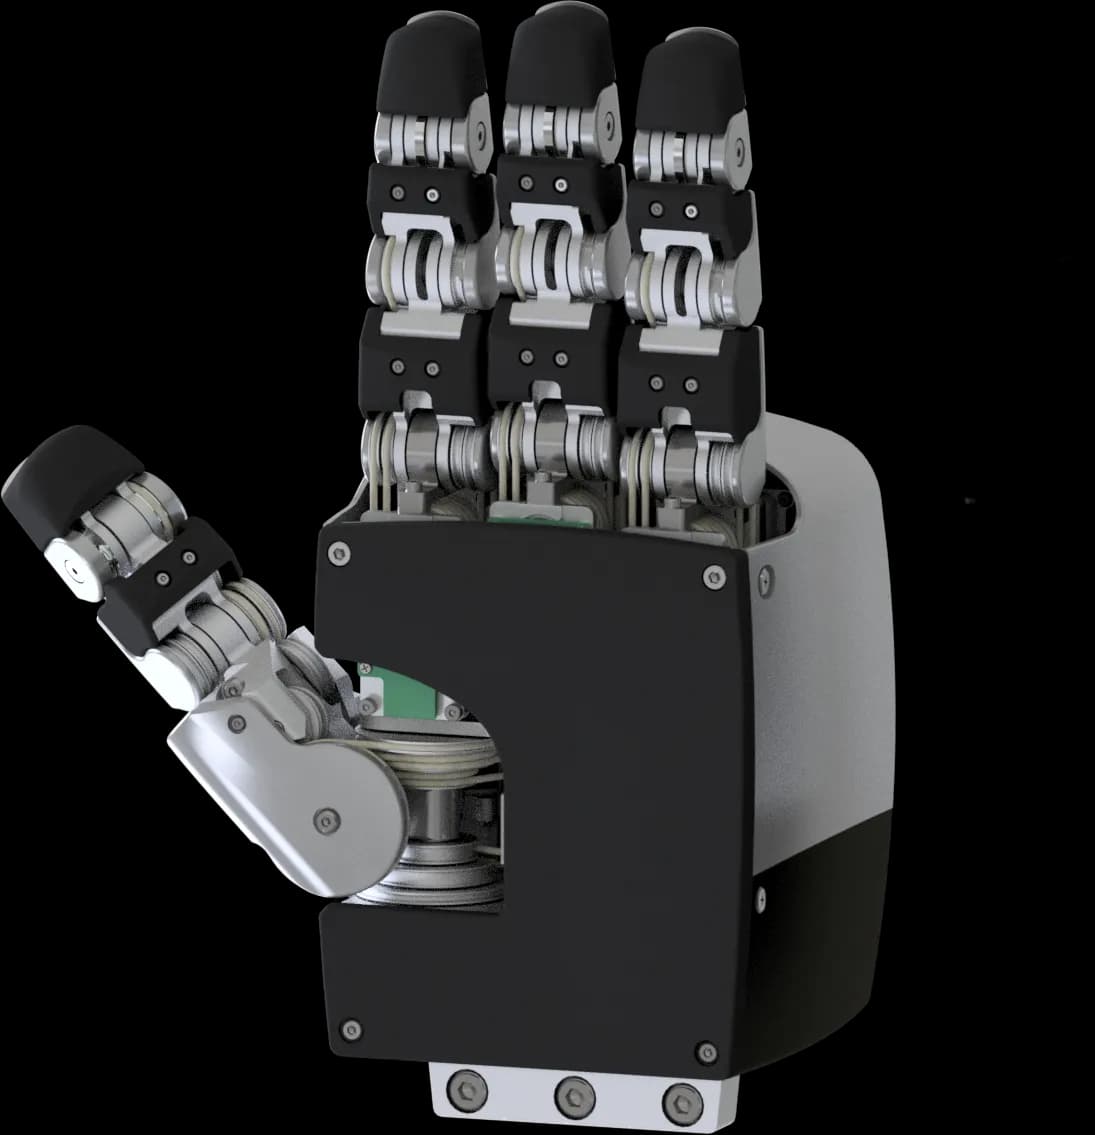
人間の手に近いサイズと構成を持つ、力覚・触覚フィードバック搭載の多指ロボットハンド

人間スケールの五指器用ハンド、22自由度と高解像度触覚センシングを備えた物理AI研究・ロボット統合向けエンドエフェクタ

舞巧于寸,肌稳于毫——20自由度仿人灵巧手,兼具精准、丝滑、疾速与有力
20自由度・高力矩透明度を備えた仿生灵巧手。触覚センシング対応、1000Hz制御周波数でモジュール式メンテナンスが可能。

仿生全能 智控稳行 —— 23自由度仿生手,毫秒级动态响应

直駆・力透明設計の仿生五指ロボットハンド。高精度力制御と視触覚融合センシングを実現。
For repeat handling of defined parts and load forms; compare four models by stroke, force, speed, payload, and installation conditions.
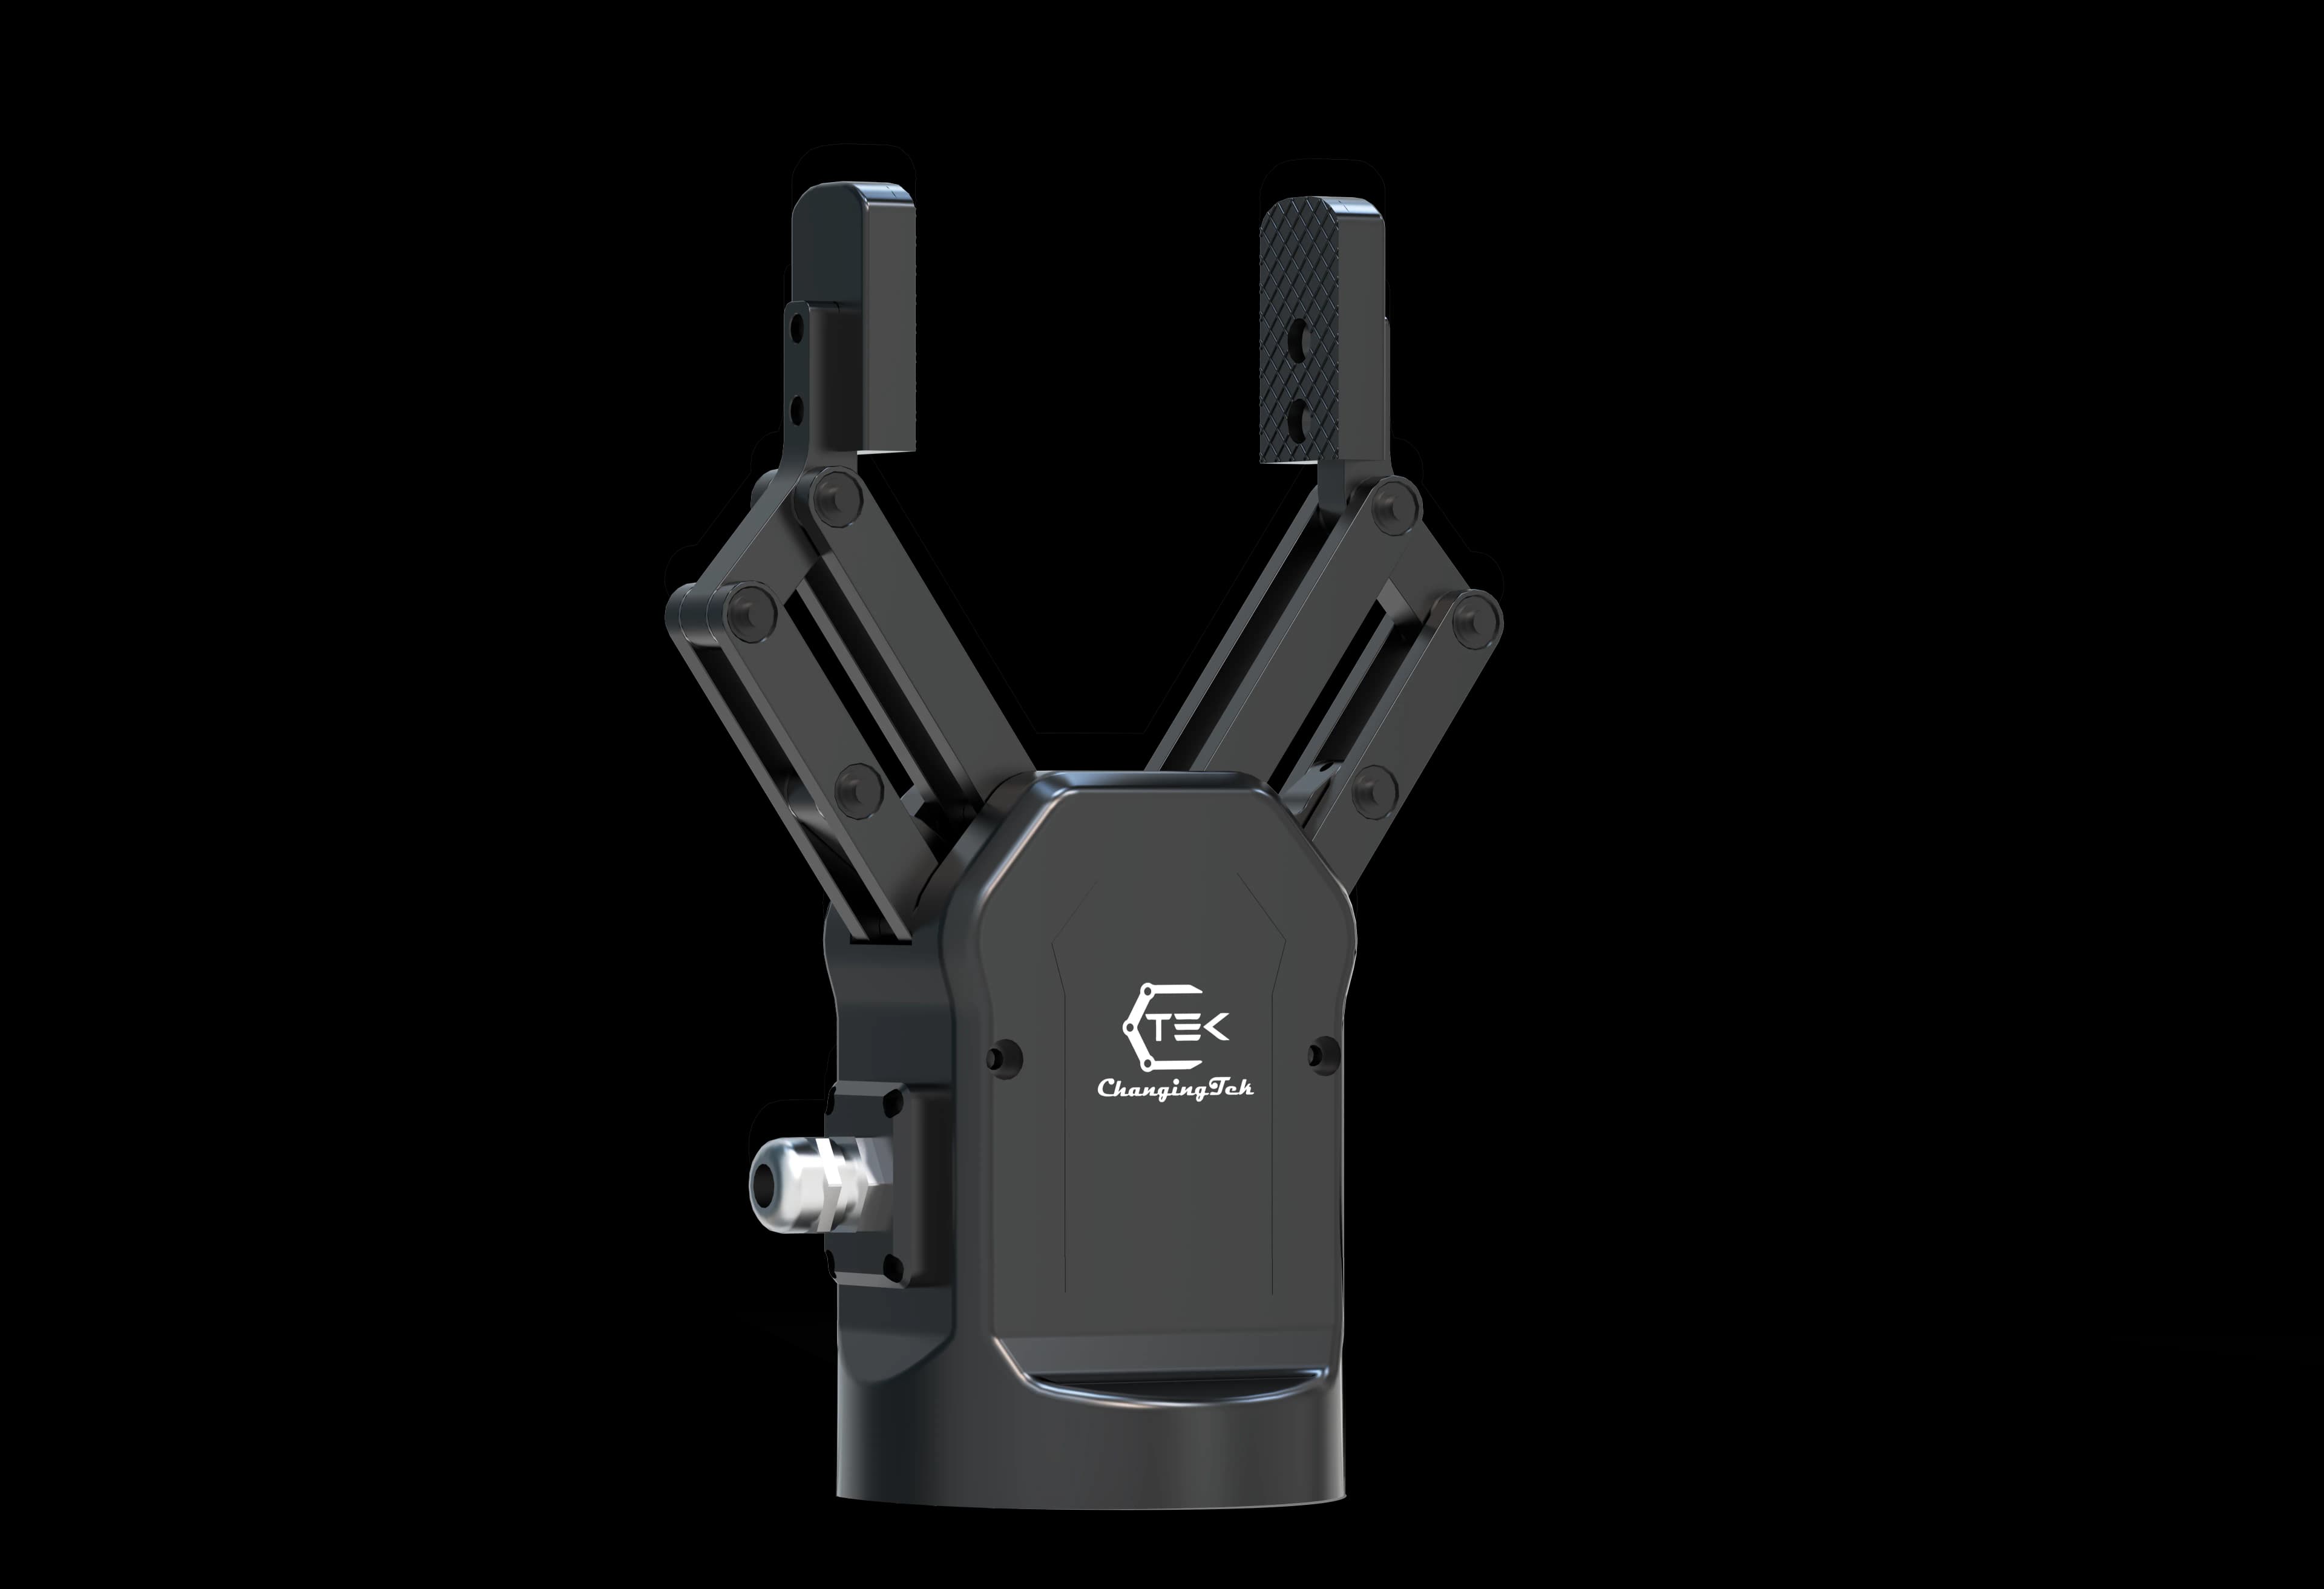
位置・速度・力のフィードバックに対応する90mmストロークの協作2指グリッパー。
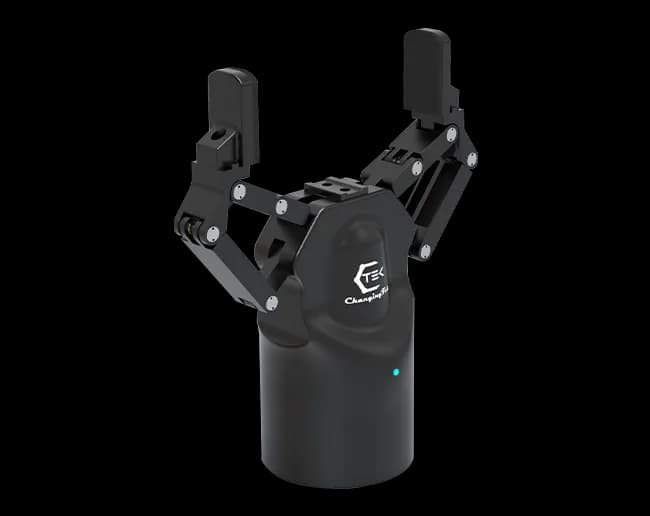
120mmの大ストロークと停電時セルフロックを備えた自適応2指グリッパー。
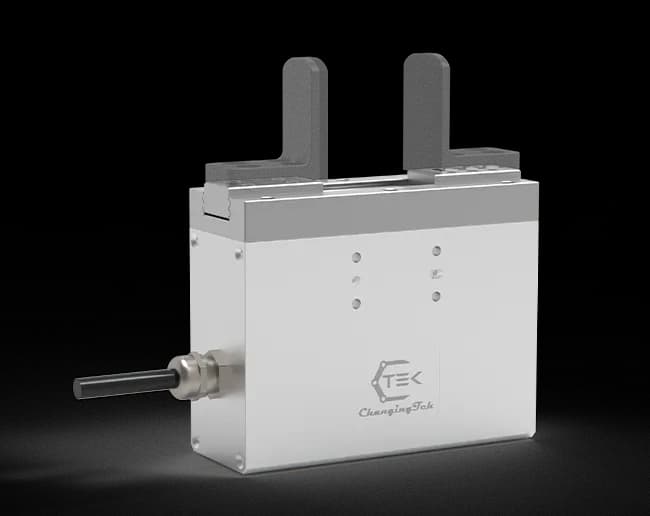
精密な位置・速度・力制御に対応する40mmストロークの工業用平行2指グリッパー。
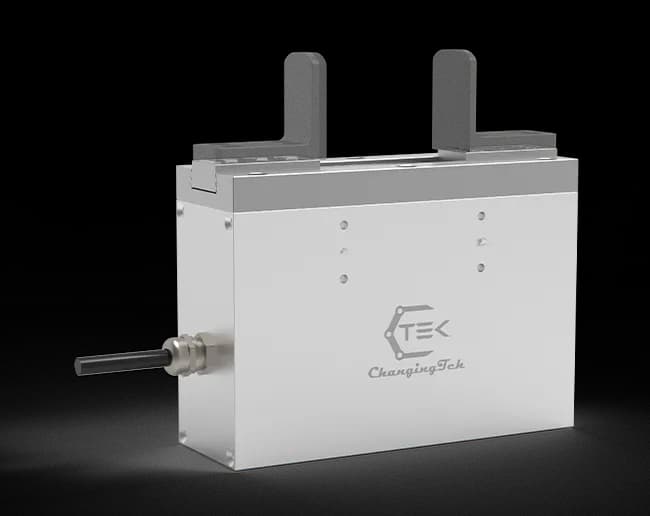
高把持力と停電時セルフロックを備えた60mmストロークの工業用平行2指グリッパー。
We help define requirements, shortlist products, and plan a measurable PoC.
Track records and partnerships are based on information published by each company.
Hi, I'm Robo-kun! Tell me what you want the robot to do and what your site looks like. We'll chat, and I'll propose up to 5 robots that fit.