SMT Board Assembly to Final Product Line at an Electronics Plant
Printing, placement, and reflow are already automated, but reel setup, odd-form insertion, connector mating, test-fixture loading, and packing still rely on people. The big advantage: cobots and humanoids can be placed directly into existing lines and compact workbenches designed for people.
16 tasks across 8 steps can move to robots.
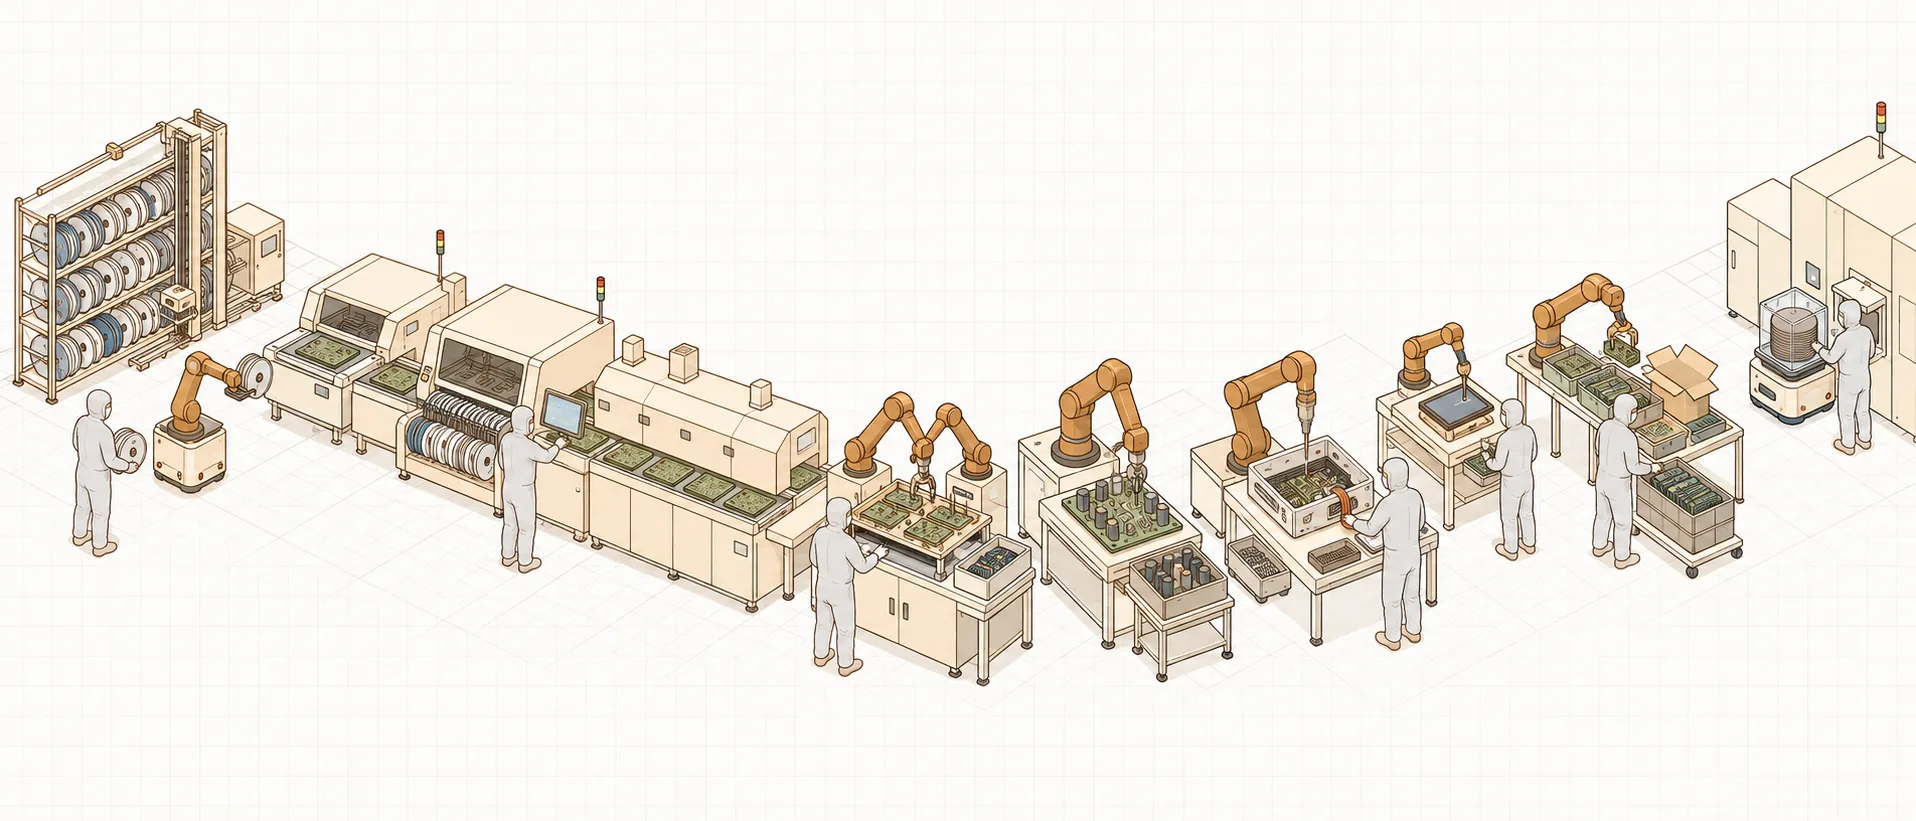
Process flow
Select a step to jump to its tasks.
- 1Receiving1 task
- 2Supply3 tasks
- 3Placement
- 4Board inspection1 task
- 5Insertion2 tasks
- 6Assembly3 tasks
- 7FCT1 task
- 8Packing & shipping2 tasks
- 9FOUP3 tasks
Process sources: 電波新聞デジタル「実装機動向」(2025-06) / サンテクノロジー SMTライン / マイナビ OKIテクノパワーシステムズ 工場レポート
Tasks by step
For each step, the tasks people do today that robots already handle somewhere. Follow the link to candidate robots and proven deployments.
- Robot-ready
Material receiving & storage
Inspect and register reels, trays, and board magazines, then move them in and out of racks or automated storage.
- Automate feeder and reel storage, issuing what each build needs from the production plan
FUJI Smart Storage (unveiled at JISSO PROTEC 2025), linked with AMRs, automated storage, and production software.
Source: 電波新聞デジタル (2025-06-04) / MONOist (2026-06-18)
- Robot-ready
Component supply & feeder setup
Load reels into feeders and carry cassettes or magazines to the placement machine for changeover.
- Loading tape reels into feeders: removing empties, reading IDs, preparing tape, and loading
FUJI Auto Kitting Station (announced May 2026, first shown at JISSO PROTEC 2026); handles 8 mm tape components.
Source: MONOist (2026-06-18) / LOGI-TODAY
- Delivering component magazines to the placement machine by AMR and swapping out empties
FUJI × Standard Robots (Shenzhen): Oasis-300E AMR feeding the NXTR A placement machine; verified at a customer site, Japan rollout in preparation (Aug 2025).
Source: LOGI-TODAY (2025-08-25)
- Unattended feeder-cassette changeover and AMR delivery of setup items such as metal masks
Yamaha Motor Change Loader AMR (concept, JISSO PROTEC 2024); Panasonic Connect multi-purpose AMR (concept, JISSO PROTEC 2023).
Source: MONOist (2024-06-18) / MONOist (2023-06-13)
- Equipment
Solder printing, placement & reflow
Printer, placement machine, and reflow oven run automatically; people handle mask changes, stock-outs, and error recovery.
Already automated by dedicated equipment; the remaining manual work (setup and replenishment) is covered in step 2.
- Robot-ready
Inspection (SPI / AOI / AXI / ICT)
SPI, AOI, and X-ray run automatically; for ICT, a person sets each board in a fixture.
- Loading high-mix boards into existing testers and fixtures, judging pass/fail by image, and sorting
Panasonic Kobe plant (2019): dual-arm robot automates board testing using the existing testers and fixtures, with no wiring, so it can be relocated.
Source: MONOist (2019-07-19)
- Robot-ready
Through-hole insertion & hand soldering
People insert large or odd-form leaded parts and run the board through wave solder; large parts are hand-soldered.
- Inserting large and odd-form leaded parts (electrolytic capacitors, coils) and driving screws
JUKI JM-E01 (on sale Dec 2024, parts up to 90 mm tall); FUJI sFAB-D and SmartWing BA (JISSO PROTEC 2024).
Source: JUKI ニュースリリース / 電波新聞デジタル (2024-06-12)
- Replacing hand soldering of large parts after reflow with a soldering robot
Laser and ultrasonic soldering robots from several Japanese makers (no named customer sites in the source).
Source: 電波新聞デジタル (2022-11-25)
- Robot-ready
Depaneling & enclosure assembly
Depanel boards, fit them into the enclosure, drive screws, and mate FPC/FFC cables to connectors.
- Inserting thin, flexible FPC/FFC cables into connectors
Sintokogio FPC auto-insertion system (force sensor detects 0.5 g changes, Dec 2023); Nachi connector-insertion application (stereo camera, connectors 5–41 mm wide).
Source: MONOist (2023-12-28) / MONOist (2021-11-25)
- Precision screwdriving and inserting HDDs or memory into server chassis
Two Mitsubishi Electric MELFA arms with force sensors hold an FPC and drive screws; MELFA inserts HDDs by feel. HIOS electric screwdriver on a UR5e (UR+ certified).
Source: 三菱電機 FA 精密ねじ締め / 三菱電機 FA サーバ組立 / MONOist (2023-02-08)
- Humanoids working on a tablet mass-production line
AGIBOT G2 at Longcheer Technology (Chinese ODM), announced Apr 2026: 19–20 s cycle, 310 units/hour. Company announcement only; tasks not disclosed.
Source: innovatopia (2026-04-16)
- Robot-ready
Functional test (FCT)
Power up the assembled product and test operation and touch panels; loading fixtures and judging results are manual.
- Touch-panel testing by pressing with a stylus and checking the response
Koyo Electronics (automotive electronics and PLCs), UR3: productivity +31%, post-inspection staff 2→1, payback about one year.
Source: Universal Robots 導入事例
- Robot-ready
Packing & shipping
Pack boards and products into trays and boxes, then move them to the shipping area.
- Placing small boards into trays and trays into boxes
Melecs EWS (Austria), UR5 with a custom gripper: three boards at a time into 54-board trays, 2 million boards a year, productivity +25%, 18-month payback.
Source: Universal Robots 導入事例
- Moving finished goods to the shipping area by AMR
OMRON Ayabe plant (Kyoto): nine AMRs plant-wide, three for shipping and one for mask magazines, dispatched by MES to the nearest free unit.
Source: MONOist (2023-08-14)
- Robot-ready
Semiconductor front-end: FOUP transport
Carry 25-wafer FOUPs to tool load ports. Overhead transport (OHT) is standard in 300 mm fabs, but carts and people remain in older fabs and back-end plants.
- Replacing cart transport of wafer boxes with AMRs and cobots
ROHM Device Manufacturing Hamamatsu plant: Adept AMRs and three cobots hand boxes through pass boxes and upper-floor sliders; lead time 60→42 days.
Source: ニュースイッチ (2026-07-01)
- Moving material and part containers between cleanroom areas
REALIZE WILL-FA AMRs for the Rapidus IIM-1 fab (Chitose, Hokkaido), announced Aug 2024.
Source: LOGI-TODAY (2024-08-27)
- Mobile manipulator moving FOUPs between load ports
KUKA KMR iisy cleanroom version (ISO 3 certified, ESD compliant), demonstrated at SEMICON West 2024.
Source: Novus Light (2024)
Summary
| Step | Robot-ready task | Stage | Robot type | Use-case guide |
|---|---|---|---|---|
| 1. Material receiving & storage | Automate feeder and reel storage, issuing what each build needs from the production plan | Product available | Autonomous Transport Robot | In-plant Transport |
| 2. Component supply & feeder setup | Loading tape reels into feeders: removing empties, reading IDs, preparing tape, and loading | PoC stage | Robot Arm | Raw Material Feeding & Supply |
| 2. Component supply & feeder setup | Delivering component magazines to the placement machine by AMR and swapping out empties | Proven overseas | Autonomous Transport Robot | In-plant Transport |
| 2. Component supply & feeder setup | Unattended feeder-cassette changeover and AMR delivery of setup items such as metal masks | PoC stage | Autonomous Transport RobotRobot Arm | In-plant Transport |
| 4. Inspection (SPI / AOI / AXI / ICT) | Loading high-mix boards into existing testers and fixtures, judging pass/fail by image, and sorting | In use in Japan | Robot Arm | Inspection & Quality Control |
| 5. Through-hole insertion & hand soldering | Inserting large and odd-form leaded parts (electrolytic capacitors, coils) and driving screws | Product available | Robot Arm | Assembly & Processing |
| 5. Through-hole insertion & hand soldering | Replacing hand soldering of large parts after reflow with a soldering robot | Product available | Robot Arm | Assembly & Processing |
| 6. Depaneling & enclosure assembly | Inserting thin, flexible FPC/FFC cables into connectors | Product available | Robot ArmRobot Hand | Assembly & Processing |
| 6. Depaneling & enclosure assembly | Precision screwdriving and inserting HDDs or memory into server chassis | Product available | Robot Arm | Assembly & Processing |
| 6. Depaneling & enclosure assembly | Humanoids working on a tablet mass-production line | PoC stage | Humanoid | Assembly & Processing |
| 7. Functional test (FCT) | Touch-panel testing by pressing with a stylus and checking the response | In use in Japan | Robot Arm | Inspection & Quality Control |
| 8. Packing & shipping | Placing small boards into trays and trays into boxes | Proven overseas | Robot Arm | Packing & Palletizing |
| 8. Packing & shipping | Moving finished goods to the shipping area by AMR | In use in Japan | Autonomous Transport Robot | In-plant Transport |
| 9. Semiconductor front-end: FOUP transport | Replacing cart transport of wafer boxes with AMRs and cobots | In use in Japan | Autonomous Transport RobotRobot Arm | In-plant Transport |
| 9. Semiconductor front-end: FOUP transport | Moving material and part containers between cleanroom areas | In use in Japan | Autonomous Transport Robot | In-plant Transport |
| 9. Semiconductor front-end: FOUP transport | Mobile manipulator moving FOUPs between load ports | PoC stage | Autonomous Transport RobotRobot Arm | In-plant Transport |
Before you deploy
- ESD: match potentials across the robot body, end-effector materials, and grounding; pick models with ESD variants.
- Cleanliness: front-end fabs are ISO class 3; check cleanroom certification and particle generation from belts and plastics.
- Placement-machine ecosystems: automatic feeder changeover and magazine delivery are tied to each maker; confirm compatibility with existing machines from other vendors.
- Packaging and size limits: reel loading automation covers a limited range (e.g., 8 mm tape); check height and weight limits for odd-form parts.
- Force sensing: FPC insertion, screwdriving, and HDD insertion usually need force control.
Discuss where to start in your own process
Bring your process chart and we will map the easiest tasks to replace, candidate robots, and a PoC plan with you.